planners/aca/jma_aca.h File Reference

#include "jma_aca_structs.h"

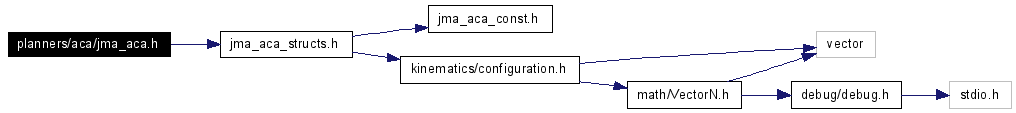
Include dependency graph for jma_aca.h:

Go to the source code of this file.

Functions

int search (JMA_Roadmap_Tree *tree, int local_planner(double[], double[]), int goal_func(double[]))
void explore (JMA_Roadmap_Tree *tree, const double distance_func(const double[], const double[]), const int random_path_proc(const int, const int, const int, const JMA_Configuration, const JMA_Configuration *))
void init_roadmap_tree (JMA_Roadmap_Tree *tree, const int n_dof, const int n_embryos, const JMA_Configuration init_conf, const double distance_func(const double[], const double[]), const int random_path_proc(const int, const int, const int, const JMA_Configuration, const JMA_Configuration *))
void update_roadmap_tree (JMA_Roadmap_Tree *tree, const double distance_func(const double[], const double[]))
void generate_new_embryo (JMA_Roadmap_Tree *tree, const int id_landmark, const int id_embryo, const double distance_func(const double[], const double[]), const int random_path_proc(const int, const int, const int, const JMA_Configuration, const JMA_Configuration *))
void compute_embryo_distance (JMA_Roadmap_Tree *tree, JMA_Configuration *embryo, double distance_func(double[], double[]))
void get_ids_path (JMA_Roadmap_Tree *tree, int landmark_id, int list_ids[], int *n_landmarks)
int get_n_ancestors (JMA_Roadmap_Tree *tree, int landmark_id)
int simplify_ids_trajectory (JMA_Roadmap_Tree *tree, int list[], int n_nodes, int ptp_collision(double[], double[]), int new_list[], int *new_n_nodes)
void print_roadmap_tree (JMA_Roadmap_Tree *)
void print_node (JMA_Node, int)


Function Documentation

void compute_embryo_distance (  JMA_Roadmap_Tree *  tree,
JMA_Configuration *  embryo,
double   distance_func(double[], double[])
) 
 

void explore (  JMA_Roadmap_Tree *  tree,
const double   distance_func(const double[], const double[]),
const int   random_path_proc(const int, const int, const int, const JMA_Configuration, const JMA_Configuration *)
) 
 

void generate_new_embryo (  JMA_Roadmap_Tree *  tree,
const int  id_landmark,
const int  id_embryo,
const double   distance_func(const double[], const double[]),
const int   random_path_proc(const int, const int, const int, const JMA_Configuration, const JMA_Configuration *)
) 
 

void get_ids_path (  JMA_Roadmap_Tree *  tree,
int  landmark_id,
int  list_ids[],
int *  n_landmarks
) 
 

int get_n_ancestors (  JMA_Roadmap_Tree *  tree,
int  landmark_id
) 
 

void init_roadmap_tree (  JMA_Roadmap_Tree *  tree,
const int  n_dof,
const int  n_embryos,
const JMA_Configuration  init_conf,
const double   distance_func(const double[], const double[]),
const int   random_path_proc(const int, const int, const int, const JMA_Configuration, const JMA_Configuration *)
) 
 

void print_node (  JMA_Node  ,
int 
) 
 

void print_roadmap_tree (  JMA_Roadmap_Tree *   ) 
 

int search (  JMA_Roadmap_Tree *  tree,
int   local_planner(double[], double[]),
int   goal_func(double[])
) 
 

int simplify_ids_trajectory (  JMA_Roadmap_Tree *  tree,
int  list[],
int  n_nodes,
int   ptp_collision(double[], double[]),
int  new_list[],
int *  new_n_nodes
) 
 

void update_roadmap_tree (  JMA_Roadmap_Tree *  tree,
const double   distance_func(const double[], const double[])
) 


Generated on Sat Apr 1 21:41:21 2006 for Motion Planning Kernel by  doxygen 1.4.6-NO