Configuration Class Reference

#include <basic/kinematics/Configuration.h>

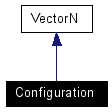
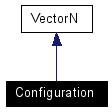
Inherits VectorN.

Inheritance diagram for Configuration:
Inheritance graph
[legend]
Collaboration diagram for Configuration:

Collaboration graph
[legend]
List of all members.

Public Member Functions

 Configuration (const VectorN &right)
 Configuration ()
virtual ~Configuration ()
void GlDraw () const
void SetNumDOF (const int dof)
bool SetJointVar (const unsigned int jointNum, const double jointVal)
const unsigned int DOF () const
double GetJointVar (const unsigned int jointNum) const
Configuration & operator= (const Configuration &right)
bool operator< (const VectorN &right) const

Detailed Description

Definition at line 8 of file Configuration.h.


Constructor & Destructor Documentation

Configuration::Configuration (  const VectorN &  right  ) 
 

Definition at line 24 of file Configuration.cpp.

Configuration::Configuration (   ) 
 

Definition at line 36 of file Configuration.cpp.

Configuration::~Configuration (   )  [virtual]
 

Definition at line 47 of file Configuration.cpp.


Member Function Documentation

const unsigned int Configuration::DOF (   )  const
 

Definition at line 76 of file Configuration.cpp.

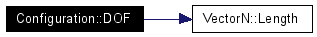
References VectorN::Length().

Referenced by PL_Astar::AlignConfig(), PL_Neural::ClampToJointLimits(), PL_RRT_ClosedChain::ConnectToGoalJacobian(), CD_JointLimits::DistanceBetween(), PL_OpenGL::Draw(), PL_RRT_CONNECT::DrawExplicit(), PL_RRT::DrawExplicit(), PL_SimplexSubdivision::DrawExplicit(), PL_Juan::DrawExplicit(), PL_ACA_CONNECT::DrawExplicit(), PL_PrmIjg::DrawOverlay(), PL_OpenGL::DrawOverlay(), PL_Range_Sensor::GenerateRandomConfig(), PL_PrmIjg::GenerateRandomConfig(), PL_GraphBase::GenerateRandomConfig(), PL_IanRandom::GenerateRandomConfig(), PL_ATACE::GenerateRandomConfig(), PL_RRT_CONNECT::Get_random_config(), PL_RRT::Get_random_config(), GetJointVar(), PL_MPEP::GetNearestNodeInGraph(), IK_InvKinBase::GetToolFrame(), PL_SimplexSubdivision::IsAdjacent(), CD_LinearDiscrete::IsInterferingLinear(), CD_LinearContinuous::IsInterferingLinearWrapping(), CD_JointLimits::JointDisplacement(), LogConfiguration(), PL_Juan::MyRandomPath(), PL_ACA_CONNECT::MyRandomPath(), ServerBase::OpenExampleFile(), PL_SimplexSubdivision::Plan(), IK_ACA::Search1(), and PL_RRT_ClosedChain::TestJacobianConnection().

Here is the call graph for this function:

double Configuration::GetJointVar (  const unsigned int  jointNum  )  const
 

Definition at line 83 of file Configuration.cpp.

References DOF(), and VectorN::operator[]().

Here is the call graph for this function:

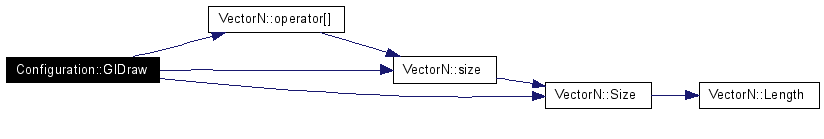
void Configuration::GlDraw (   )  const
 

Definition at line 96 of file Configuration.cpp.

References VectorN::operator[](), VectorN::size(), and VectorN::Size().

Here is the call graph for this function:
bool Configuration::operator< (  const VectorN &  right  )  const
 

Definition at line 133 of file Configuration.cpp.

Configuration & Configuration::operator= (  const Configuration &  right  ) 
 

Definition at line 121 of file Configuration.cpp.

References VectorN::operator=().

Here is the call graph for this function:

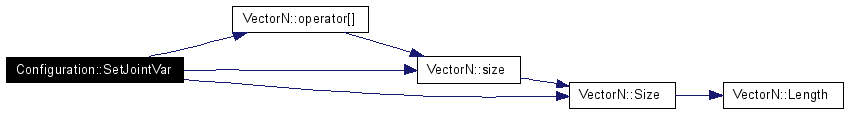
bool Configuration::SetJointVar (  const unsigned int  jointNum,
const double  jointVal
) 
 

Definition at line 63 of file Configuration.cpp.

References VectorN::operator[](), VectorN::Size(), and VectorN::size().

Referenced by CRedundant::CombineConfiguration().

Here is the call graph for this function:
void Configuration::SetNumDOF (  const int  dof  ) 
 

Definition at line 56 of file Configuration.cpp.

References VectorN::SetLength().

Referenced by PL_Astar::AlignConfig(), CJacobian::CJacobian(), PL_Sequential::compute_a_column_for_link_cspace(), and PL_GraphBase::GetCspaceRange().

Here is the call graph for this function:


The documentation for this class was generated from the following files:
Generated on Sat Apr 1 21:46:14 2006 for Motion Planning Kernel by  doxygen 1.4.6-NO